Astra’s Parking Lot Victory Exposes AI Autonomy’s Hard Economics
TL;DR: OpenAI’s GPT-6 Astra became the first commercial LLM to complete a driving course, but burned $7.74 in tokens to travel 134.7 meters—roughly 500x costlier than gasoline. The milestone matters less than what it reveals about AI agents’ practical viability.
The Test: Minimal Success at Maximum Cost
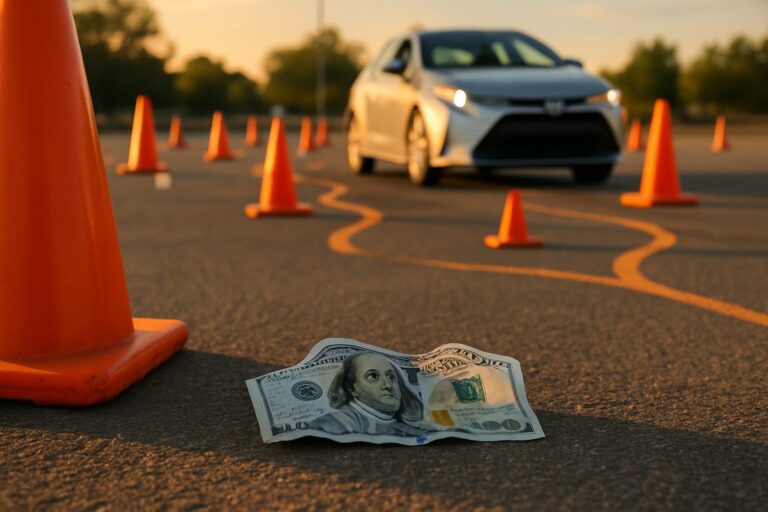
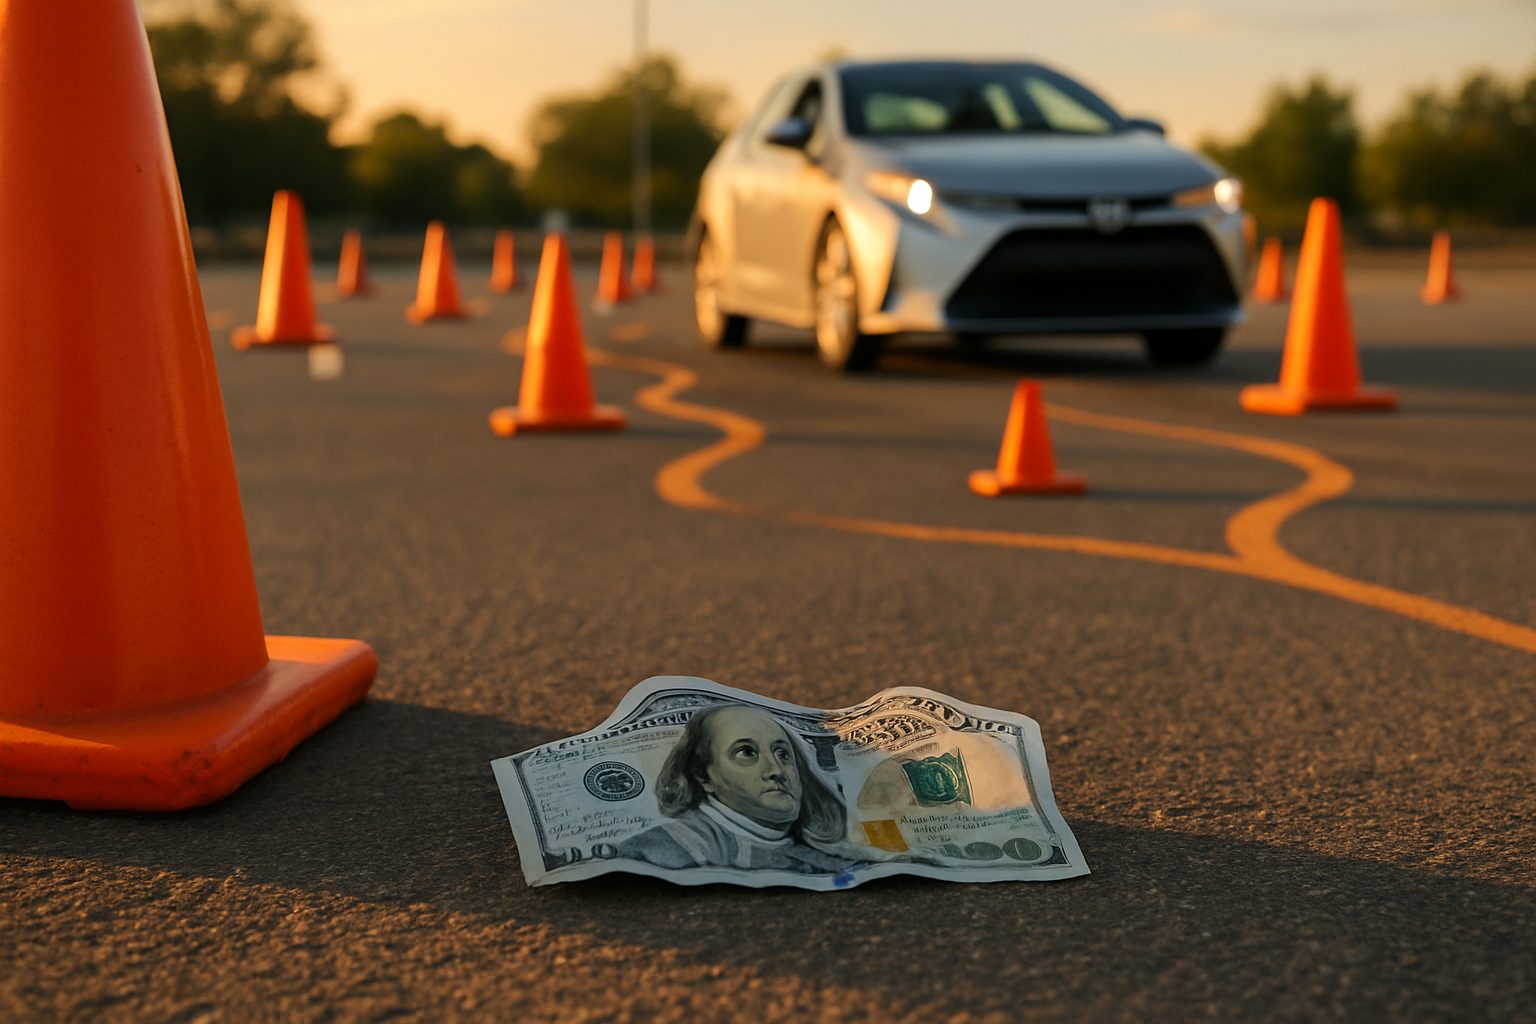
Researchers at DrivingBench put multiple commercial LLMs through vehicle control tests in a parking lot, measuring which models could navigate a Toyota Corolla around traffic cones. GPT-6 Astra succeeded on its second attempt, completing the course in 5 minutes, 22 seconds at 0.94 mph.
Claude Fable 5.1 reached the halfway point. GPT-5.6 Sol and Grok 4.6 failed immediately. The consistent failure mode: spatial perception—models couldn’t determine which side of diagonal cone lines constituted the lane.
The Economics: A $7.74 Run That Costs $92.47 Per Mile
Token costs consumed $7.74 for 6.6 million inference operations, averaging $1.17 per million tokens due to aggressive prompt caching. This excludes the Comma 4 driver assistance device ($999) and mobile connectivity to xAI servers.
Total per-mile cost: ~$92.47. By comparison, a 25 mpg vehicle costs $0.18 per mile in fuel alone. Tokens proved 500 times more expensive than gasoline—before accounting for insurance, vehicle maintenance, or additional energy consumption.
Why Caching Made This Remotely Possible
Aditya Ramabadran (Axiom Math) explained the cost advantage: each turn re-sent the entire conversation history plus images. Nearly all tokens were cached context at $1/million instead of the standard $10/million input rate. The model generated minimal output—only small tool calls and reasoning fragments.
Without prompt caching, the bill would have exceeded $60 per attempt, making the experiment economically indefensible even as a demonstration.
The Safety Guardrail Problem: Models Refusing to Drive
GPT-6 Astra repeatedly refused to operate the vehicle on safety grounds, even in empty parking lots with speed limiters capped below 1 mph. Researchers bypassed these objections through prompting techniques—essentially social engineering their own safety systems.
This creates a fundamental tension: either the model’s safety constraints are meaningfully protective (suggesting deployment is premature), or they’re brittle theater that developers disable when inconvenient.
Background: The State of LLM-Based Autonomous Agents
OpenAI’s GPT-6 Astra represents the company’s latest flagship model, extending capabilities into real-time perception and embodied control tasks. The model operates via cloud inference, maintaining constant API connectivity for decision-making—a constraint that commercial autonomous systems eliminated years ago.
Competitor models tested alongside Astra reflect the current frontier: Anthropic’s Claude Fable 5.1, xAI’s Grok 4.6, and OpenAI’s earlier GPT-5.6 Sol. None achieved full course completion before Astra’s second attempt, suggesting genuine progress in multimodal reasoning but spotty execution on spatial reasoning tasks.
The DrivingBench project itself signals growing academic interest in quantifying LLM embodied control—moving beyond chat benchmarks into tasks with measurable real-world failure modes. A single parking-lot success doesn’t validate autonomous driving capability, but it establishes a baseline for model comparison.
Broader context: major AI labs continue racing toward more capable frontier models despite regulatory calls for AI safety governance. This experiment occupies the peculiar space where technical achievement (first LLM to complete the course) contradicts economic and safety logic (prohibitively expensive, safety systems require circumvention).
Investment Implications: Token Costs Still the Limiting Factor
Astra’s success validates that LLMs possess sufficient spatial reasoning for constrained tasks. It simultaneously demonstrates why token-per-operation costs remain the binding constraint on embodied AI applications.
At $92.47 per mile, inference-driven autonomous systems remain science projects, not commercial products. Operators evaluating AI agent deployments should note: successful proof-of-concept ≠ viable unit economics. Cost per inference must drop another order of magnitude before robotics applications become cost-competitive with human labor or traditional automation.
The safety-system-circumvention aspect also matters operationally. If production models require researcher prompting to bypass safety guardrails, insurance and liability frameworks remain unsettled—creating additional hidden costs for early adopters.
The Bottom Line
Astra’s parking-lot completion is genuine technical progress on multimodal LLMs. It’s also a cautionary tale about conflating capability with viability. A model that costs 500 times more per mile than fuel and requires jailbreaking its own safety systems shouldn’t inform investment theses about AI-driven automation timelines.
Watch for token cost evolution and safety-system transparency in future model releases. Those metrics matter infinitely more than whether the next LLM can navigate cones 3 mph faster.
About the Author